Juan David H.
Mechatronics & Electronics Engineer - complete IoT prototypes: PCB design, ESP32 firmware and 3D CAD
 Cartagena,
Colombia
Global rank:
1,239
/
151,705
Skill pts: 35
About
Mechatronics Engineer and Electronics Engineer (dual degree, Universidad Tecnologica de Bolivar, Colombia), with active professional licenses in both fields.
I work where electronics and mechanics meet: PCBs, the enclosures that house them, and getting the hardware to actually work once it is built. Most CAD designers do not understand the electronics going inside the part, and most electronics designers do not model the housing.
WHAT I DO
- PCB design: schematic capture, routing, Gerbers, BOM and manufacturing files
- Hardware bring-up, testing and validation: sensors, actuators, firmware, communication links
- ESP32 and Arduino firmware in C/C++: sensors, WiFi, Bluetooth, MQTT, TCP
- 3D CAD: parts, enclosures and cabinets, delivered as native files, STEP and STL
- Control systems: PID and fuzzy logic, with experimental validation
- Technical documentation: interconnection diagrams, power budgets, test protocols
EXPERIENCE
At COTECMAR, a naval science and technology corporation, I spent six months on systems integration. I designed the communication architecture combining RS-422, TCP/IP Ethernet and radio modems; modelled the system cabinet in 3D at 1:1 scale, integrating 8 subsystems and migrating it from rack format to a portable enclosure; produced 6 electrical interconnection diagrams adopted as project reference documentation; and ran the laboratory test protocol validating the communication links.
SELECTED WORK
- SwarMind (final-year team project, 3 authors): a swarm of 10 autonomous robots. I designed the double-sided octagonal PCB through 4 iterations, integrating the ESP32, 8 perimeter infrared sensors, motor control and battery monitoring, replicated across all 10 units. I also ran the experimental validation: in a 2x2 m arena, 7 of the 10 robots converged on the target zone in about one minute.
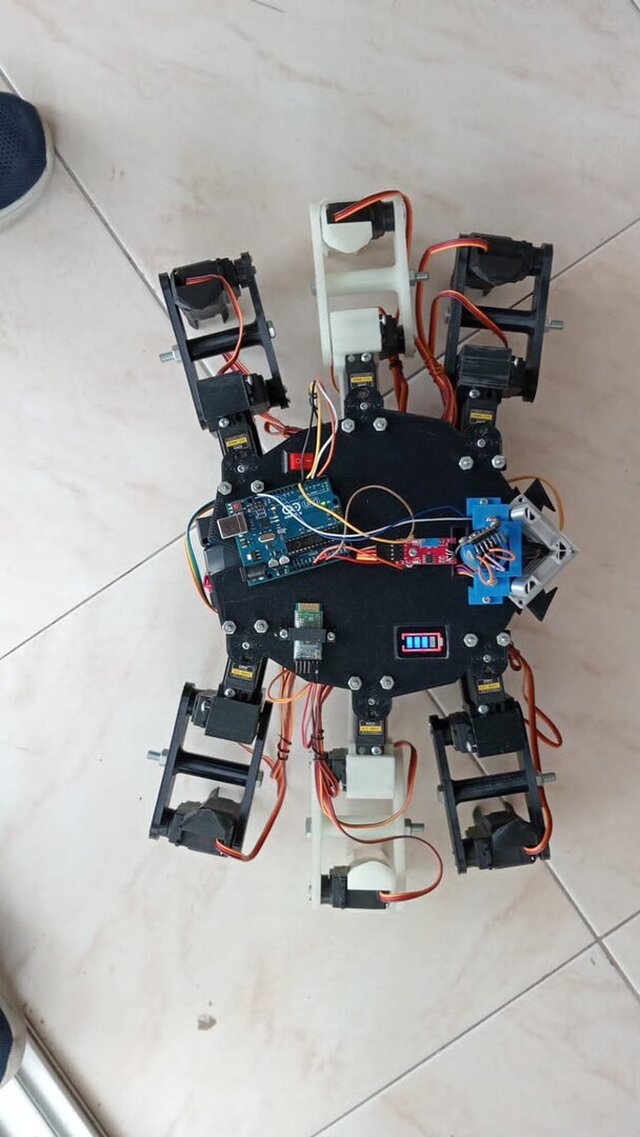
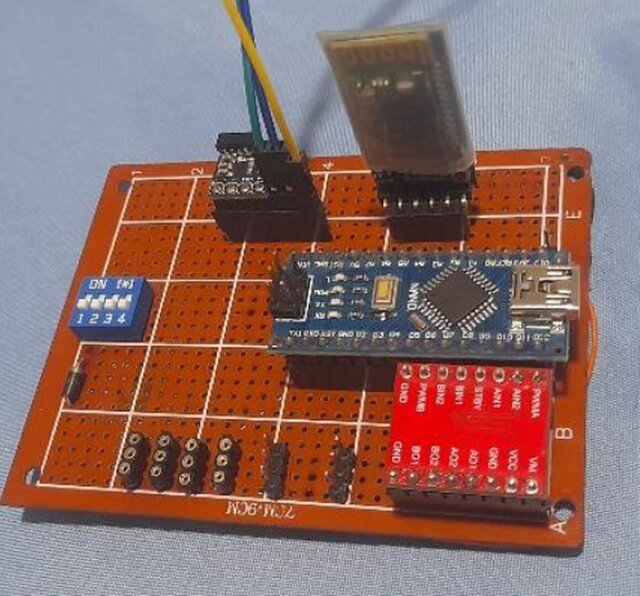
- MiniSumo competition robot: I designed the PCB and the autonomous and Bluetooth control system, and handled testing and validation of the sensors, actuators and control code. Second place, UTBot Robotic People Fest 2023.
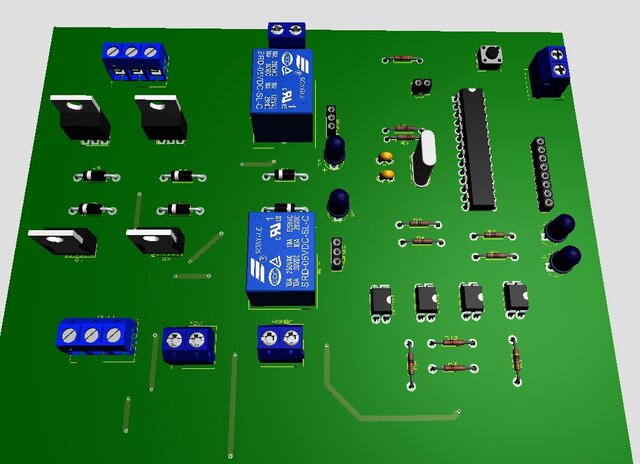
- Digital viscometer (team project): I produced the wiring diagram, implemented fuzzy-logic temperature control over Peltier cells via PWM, and redesigned the power stage after two thermal failures, converging on a topology with reversing relays and independent PWM regulation per cell. Validated viscosity curve from 25 to 50 C.
HOW I WORK
I deliver with technical documentation: power budgets, torque and autonomy calculations, design rationale and manufacturing-ready files. I am explicit about what I did personally and what was team work, and if something is not feasible I say so before we start, not at the end.
Native Spanish. Certified C1 English (EF SET). Available immediately.
... more »
« less
I work where electronics and mechanics meet: PCBs, the enclosures that house them, and getting the hardware to actually work once it is built. Most CAD designers do not understand the electronics going inside the part, and most electronics designers do not model the housing.
WHAT I DO
- PCB design: schematic capture, routing, Gerbers, BOM and manufacturing files
- Hardware bring-up, testing and validation: sensors, actuators, firmware, communication links
- ESP32 and Arduino firmware in C/C++: sensors, WiFi, Bluetooth, MQTT, TCP
- 3D CAD: parts, enclosures and cabinets, delivered as native files, STEP and STL
- Control systems: PID and fuzzy logic, with experimental validation
- Technical documentation: interconnection diagrams, power budgets, test protocols
EXPERIENCE
At COTECMAR, a naval science and technology corporation, I spent six months on systems integration. I designed the communication architecture combining RS-422, TCP/IP Ethernet and radio modems; modelled the system cabinet in 3D at 1:1 scale, integrating 8 subsystems and migrating it from rack format to a portable enclosure; produced 6 electrical interconnection diagrams adopted as project reference documentation; and ran the laboratory test protocol validating the communication links.
SELECTED WORK
- SwarMind (final-year team project, 3 authors): a swarm of 10 autonomous robots. I designed the double-sided octagonal PCB through 4 iterations, integrating the ESP32, 8 perimeter infrared sensors, motor control and battery monitoring, replicated across all 10 units. I also ran the experimental validation: in a 2x2 m arena, 7 of the 10 robots converged on the target zone in about one minute.
- MiniSumo competition robot: I designed the PCB and the autonomous and Bluetooth control system, and handled testing and validation of the sensors, actuators and control code. Second place, UTBot Robotic People Fest 2023.
- Digital viscometer (team project): I produced the wiring diagram, implemented fuzzy-logic temperature control over Peltier cells via PWM, and redesigned the power stage after two thermal failures, converging on a topology with reversing relays and independent PWM regulation per cell. Validated viscosity curve from 25 to 50 C.
HOW I WORK
I deliver with technical documentation: power budgets, torque and autonomy calculations, design rationale and manufacturing-ready files. I am explicit about what I did personally and what was team work, and if something is not feasible I say so before we start, not at the end.
Native Spanish. Certified C1 English (EF SET). Available immediately.
Experience
-
Engineering Intern - Science, Technology and Innovation Division
COTECMAR · Internship
Oct 2025 –
Apr 2026
6 mos
Cartagena, Bolivar, Colombia
Six-month engineering internship at COTECMAR, a naval science and technology corporation in Cartagena, Colombia.
- Designed the communication architecture of a portable systems-integration platform, combining RS-422 serial links, TCP/IP Ethernet networks and radio modems so heterogeneous subsystems could interoperate on a single platform.
- Evaluated 14 industrial hardware alternatives (processors, Ethernet relay boards, switches, modems and serial-to-Ethernet converters) against robustness, compatibility and field maintainability criteria, and replaced 5 components of the initial configuration with industrial-grade options.
- Programmed the Ethernet relay board control modules in C++ and integrated them into the general code base.
- Modelled the system cabinet in 3D at 1:1 scale, integrating 8 subsystems and migrating the design from rack format to a portable cabinet to meet deployment requirements.
- Produced 6 electrical interconnection diagrams (power, data and control signals), adopted as project reference documentation.
- Executed the laboratory test protocol validating communication between radios and modems, including pinout mapping and cable fabrication.
Hardware-software integration on real equipment, in a high-requirement engineering environment.
Education
- Universidad Tecnologica de Bolivar Mechatronics Engineer and Electronics Engineer (dual degree), Mechatronics Engineering 2020 – 2026 Dual degree: graduated simultaneously as Mechatronics Engineer and Electronics Engineer on May 8, 2026, with active professional licenses in both fields. Caribe Leadership Scholarship (2020-2025). Final-year project: SwarMind, a 10-robot autonomous swarm with ESP32, four PCB iterations and a PyQt5 control interface with computer vision.
Licenses & Certifications
- EF SET English Certificate - C1 Advanced (64/100) May 2026 – Present See credential
Verified info
- Government ID
Stats
0 followers, 0 following
Joined: September 7, 2026
Last seen: October 11, 2026
Area of Expertise
Languages
Spanish Native or bilingual proficiency
English Professional working proficiency
Location
Cartagena, Colombia