

BotZilla Mini Sumo Robot - Control Electronics and Wiring Design (2nd place)
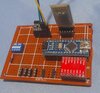
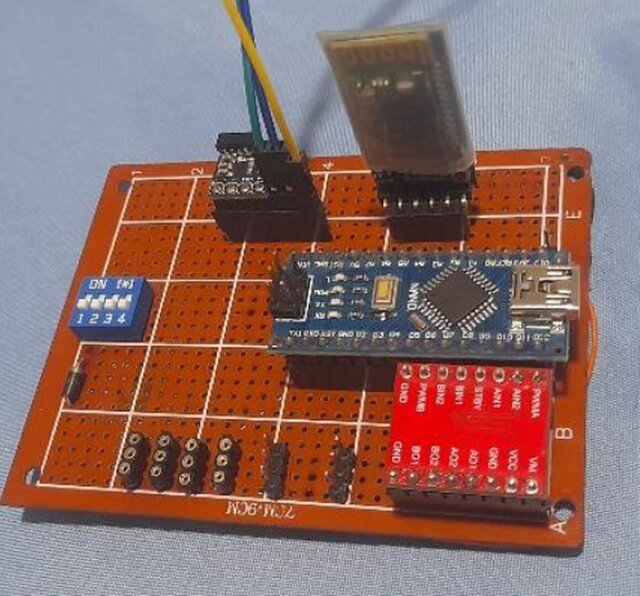
Control electronics I designed and built for BotZilla, an autonomous mini sumo combat robot that took 2nd place at the UTBot Robotic People Fest 2023.
WHAT THE BOARD DOES
One board carries the whole robot: an ATmega328P (Arduino Nano) reading six detection sensors, an HC-05 Bluetooth module for telemetry and manual override, a 4-position DIP switch for selecting the match strategy without reprogramming, and a TB6612FNG dual H-bridge driving the two combat motors from a 9V rail.
SENSOR LAYOUT
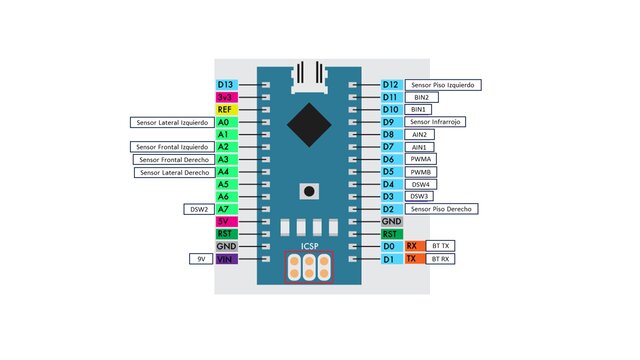
- 2 floor sensors, left and right, that detect the white edge of the ring so the robot stops before being pushed out.
- 4 opponent sensors: two frontal and two lateral, which give the search routine a direction instead of a blind spin.
- 1 additional infrared input.
DESIGN DECISIONS
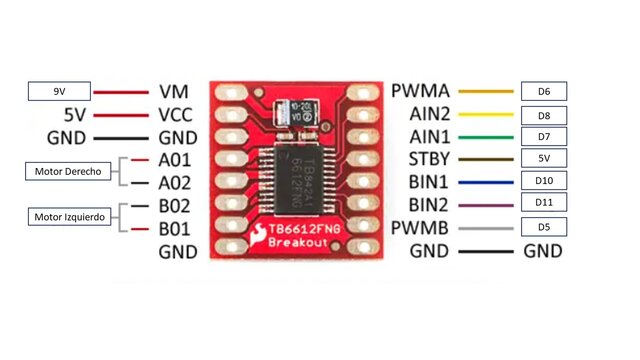
- Every signal was assigned on paper before anything was wired. The two pin-map sheets in this gallery are the actual documents I built the robot from, and they are what made the wiring reproducible after a crash.
- Motor PWM sits on hardware PWM pins (D5 and D6) and the four direction lines on adjacent pins, so the control code writes them together.
- The Bluetooth module sits on the hardware UART (D0/D1), not on a software serial port, because dropped characters during a match are not recoverable.
- The DIP switch reads on three digital inputs, so the strategy can be changed between rounds in seconds. With only minutes between matches in a competition, that is worth more than it sounds.
- STBY tied to 5V and the 9V motor rail kept separate from the 5V logic rail, to keep motor noise out of the microcontroller.
- Every module is socketed on headers: a part damaged in a collision is swapped in under a minute.
RESULT
2nd place, UTBot Robotic People Fest 2023. The robot ran both fully autonomously and under Bluetooth manual control.
Note on scope: this board was hand-assembled on prototyping board, not manufactured. What is shown here is the circuit and the wiring architecture. For a fully routed, manufactured and assembled PCB of mine, see my SwarMind entry.
Published