I offer 3D modeling with laser triangulation & LiDAR point-cloud simulation (Python/OpenCV)


About this service
I build laser-triangulation 3D scanning software and LiDAR point-cloud models and simulations: calibration, 3D reconstruction, dimensional measurement and visualization in Python.
Full description:
I turn camera + line-laser images into calibrated 3D models, and I model and simulate LiDAR scans and point clouds.
Proven project: laser-triangulation 3D scanner
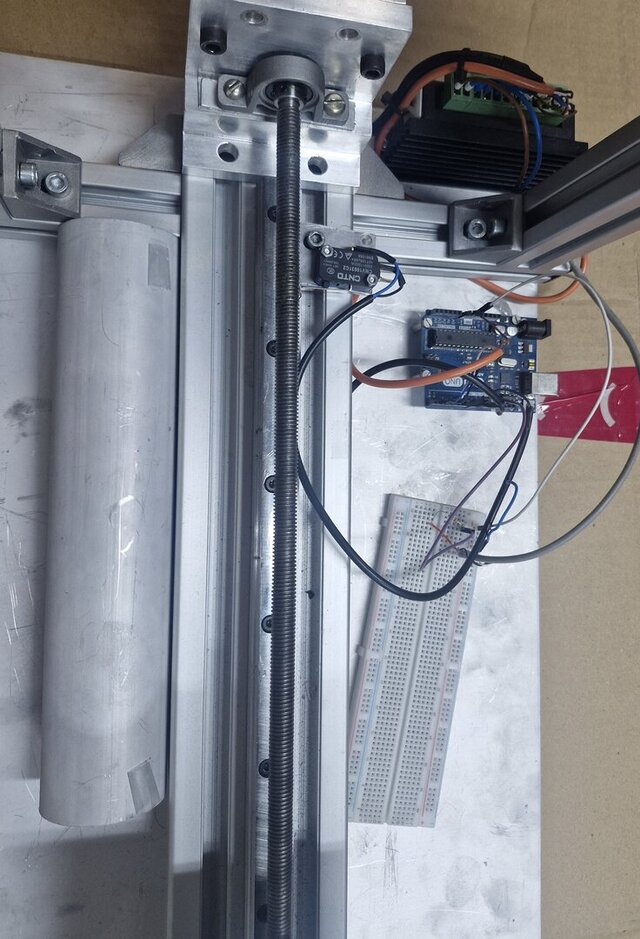
- Wrote the full software for a single-camera line-laser scanner on a stepper-driven motion stage.
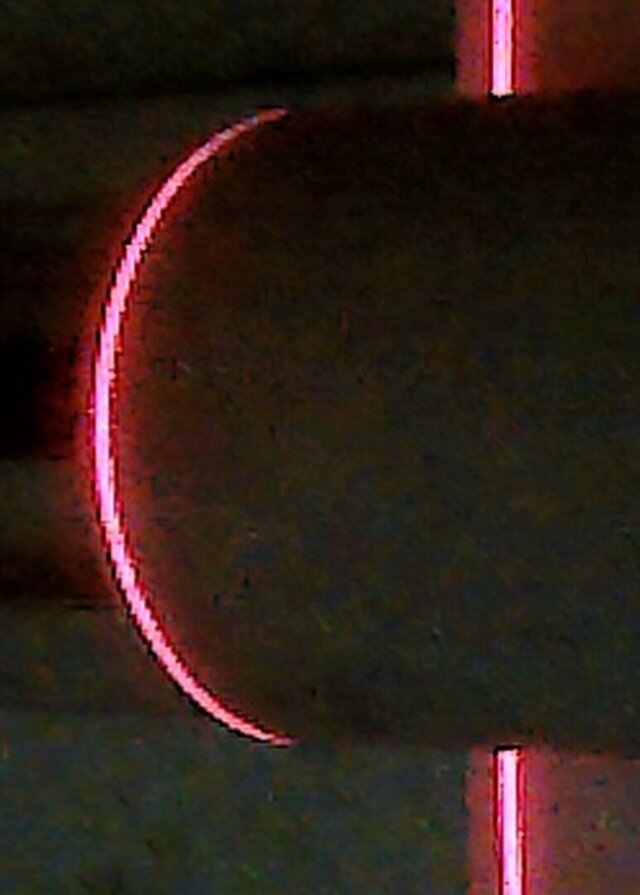
- Camera calibration and lens undistortion, laser-line extraction (HSV, CLAHE, morphology, skeletonization) and ray–laser-plane triangulation.
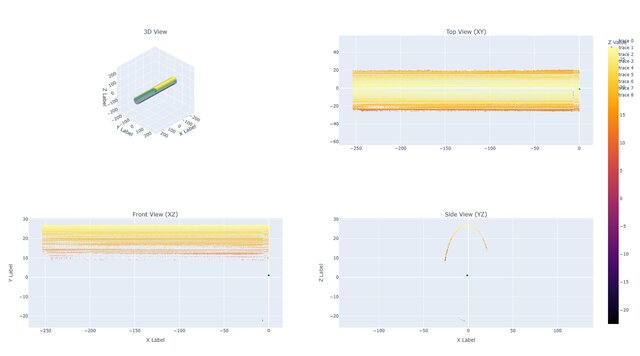
- Profiles stacked by scan step into a dense 3D point cloud, then transformed into a CAD-aligned world frame (extrinsics fitted with SciPy).
- Measured pipe radius and form against an ideal cylinder, at a 0.01 mm project accuracy target.
- Checked the camera, laser and world frames in AutoCAD before writing any code.
What I offer:
1. Laser-triangulation scanner software: calibration, laser-line detection, 3D reconstruction and export to PLY/XYZ/CSV.
2. LiDAR modeling and simulation: ray-casting simulation of LiDAR scans on CAD/mesh scenes (sensor pose, FOV, resolution, range noise), so you can check sensor placement and coverage before buying hardware.
3. Point-cloud processing: filtering, downsampling, registration, plane/circle/cylinder fitting, measurement and deviation-from-CAD reports.
4. Visualization: interactive 3D/2D views (Open3D, Plotly) and clear technical documentation... read more
I build laser-triangulation 3D scanning software and LiDAR point-cloud models and simulations: calibration, 3D reconstruction, dimensional measurement and visualization in Python.
Full description:
I turn camera + line-laser images into calibrated 3D models, and I model and simulate LiDAR scans and point clouds.
Proven project: laser-triangulation 3D scanner
- Wrote the full software for a single-camera line-laser scanner on a stepper-driven motion stage.
- Camera calibration and lens undistortion, laser-line extraction (HSV, CLAHE, morphology, skeletonization) and ray–laser-plane triangulation.
- Profiles stacked by scan step into a dense 3D point cloud, then transformed into a CAD-aligned world frame (extrinsics fitted with SciPy).
- Measured pipe radius and form against an ideal cylinder, at a 0.01 mm project accuracy target.
- Checked the camera, laser and world frames in AutoCAD before writing any code.
What I offer:
1. Laser-triangulation scanner software: calibration, laser-line detection, 3D reconstruction and export to PLY/XYZ/CSV.
2. LiDAR modeling and simulation: ray-casting simulation of LiDAR scans on CAD/mesh scenes (sensor pose, FOV, resolution, range noise), so you can check sensor placement and coverage before buying hardware.
3. Point-cloud processing: filtering, downsampling, registration, plane/circle/cylinder fitting, measurement and deviation-from-CAD reports.
4. Visualization: interactive 3D/2D views (Open3D, Plotly) and clear technical documentation.
Tools:
- Python
- OpenCV
- NumPy
- SciPy
- Scikit-image
- Open3D
- Plotly
- AutoCAD
Deliverables:
Documented Python source code, calibration files, point clouds (PLY/XYZ), plots and a short report. read less
I build laser-triangulation 3D scanning software and LiDAR point-cloud models and simulations: calibration, 3D reconstruction, dimensional measurement and visualization in Python.
Full description:
I turn camera + line-laser images into calibrated 3D models, and I model and simulate LiDAR scans and point clouds.
Proven project: laser-triangulation 3D scanner
- Wrote the full software for a singl... read more
Full description:
I turn camera + line-laser images into calibrated 3D models, and I model and simulate LiDAR scans and point clouds.
Proven project: laser-triangulation 3D scanner
- Wrote the full software for a singl... read more
I build laser-triangulation 3D scanning software and LiDAR point-cloud models and simulations: calibration, 3D reconstruction, dimensional measurement and visualization in Python.
Full description:
I turn camera + line-laser images into calibrated 3D models, and I model and simulate LiDAR scans and point clouds.
Proven project: laser-triangulation 3D scanner
- Wrote the full software for a single-camera line-laser scanner on a stepper-driven motion stage.
- Camera calibration and lens undistortion, laser-line extraction (HSV, CLAHE, morphology, skeletonization) and ray–laser-plane triangulation.
- Profiles stacked by scan step into a dense 3D point cloud, then transformed into a CAD-aligned world frame (extrinsics fitted with SciPy).
- Measured pipe radius and form against an ideal cylinder, at a 0.01 mm project accuracy target.
- Checked the camera, laser and world frames in AutoCAD before writing any code.
What I offer:
1. Laser-triangulation scanner software: calibration, laser-line detection, 3D reconstruction and export to PLY/XYZ/CSV.
2. LiDAR modeling and simulation: ray-casting simulation of LiDAR scans on CAD/mesh scenes (sensor pose, FOV, resolution, range noise), so you can check sensor placement and coverage before buying hardware.
3. Point-cloud processing: filtering, downsampling, registration, plane/circle/cylinder fitting, measurement and deviation-from-CAD reports.
4. Visualization: interactive 3D/2D views (Open3D, Plotly) and clear technical documentation.
Tools:
- Python
- OpenCV
- NumPy
- SciPy
- Scikit-image
- Open3D
- Plotly
- AutoCAD
Deliverables:
Documented Python source code, calibration files, point clouds (PLY/XYZ), plots and a short report. read less
Service offer categories
2D to 3D Modeling
Reverse Engineering
3D Design Services
Software & skills
3D Laser Scanning
AutoCAD
LiDAR Mapping
Metrology
Reverse Engineering
+2 more
Member since
September 2026
Languages
English,
Persian (Farsi),
Armenian
Avg. response time
1 hour
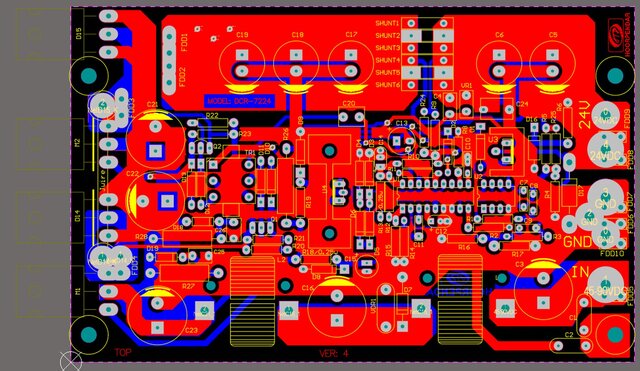
Electrical & PCB Design Engineer | Altium · Power Electronics · Embedded / Raspberry Pi - Python P
Electrical engineer and PCB designer with 6+ years of end-to-end board development. I take projects from schematic capture and component selection in Altium Designer through multi-layer layout, Gerber/BOM packages, fabrication and assembly, and lab bring-up.
What I can do for you:
• PCB schematic & layout (2-layer to multi-layer)
• Power electronics — battery chargers, DC-DC converters, thyristor... read more
What I can do for you:
• PCB schematic & layout (2-layer to multi-layer)
• Power electronics — battery chargers, DC-DC converters, thyristor... read more

Cad Crowd Billing Security policy
Service quality is protected by Cad Crowd Billing Security policy.
More from Arash P.
More similar services
See related services
- 3D Design services
- 3D Modeling services
- CAD Design services
- 3D CAD Design services
- 2D & 3D Design services
- CAD Modeling services
- 3D CAD Modeling services
- 2D & 3D Modeling services
- Engineering Design services
- 2D & 3D CAD Design services
- Drafting services
- AutoCAD services
- Mechanical Design services
- 3D Models services
- Mechanical 3D Design services
- Design for Manufacturing services
- 2D Drawing services
- 2D Drafting services
- Product Design services
- CAD Drafting services
- 2D AutoCAD services
- Rendering services
- SolidWorks services
- Mechanical Engineering services
- Architectural Design services
- 3D Rendering services
- 3D Solidworks services
- Manufacturing Drawings services
- 2D & 3D Drafting services
- 2D/3D AutoCAD services
- Assembly Design services
- 2D & 3D Modeling Solidworks services
- Engineering Drawing services
- Mechanical Engineer services
- Design Engineer services
- Industrial Design services