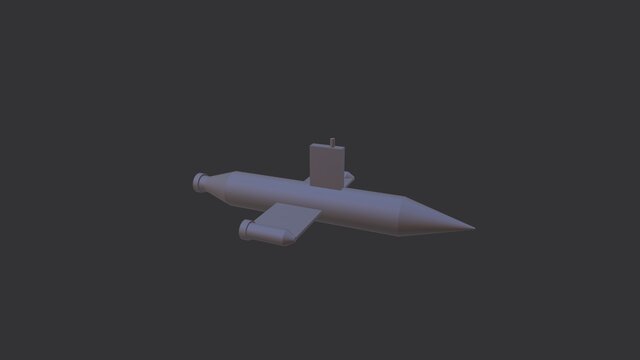
3D

semisub_hull
What I did: I designed the full schematic in EasyEDA. The design includes:
- Dual-battery input through AS150 connectors, with a 300A main power fuse feeding a power distribution block and a converter output
- Three thruster channels, each with its own inline fuse holder and a dedicated signal header, so one thruster fault can't take down the others
- Four servo headers with signal, power, and ground
- Two GPS ports and two telemetry ports with TX/RX and CTS/RTS lines
- Two leak sensor inputs for water-ingress detection
- 5V and 9V converter inputs with LED power indicators
- Organized, labeled sections and an on-sheet note flagging that the Pixhawk throttle output must be limited to 60% to run a 6S battery safely on the T200 thrusters without overheating
Files (1)
License:
CC - Attribution
Learn more
Published
in
CAD Design