

3D

3D

3D

3D

3D

3D

3D

4:1 Planetary Gearbox for NEMA 23: Involute Gears with Gear Data Drawing
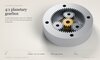
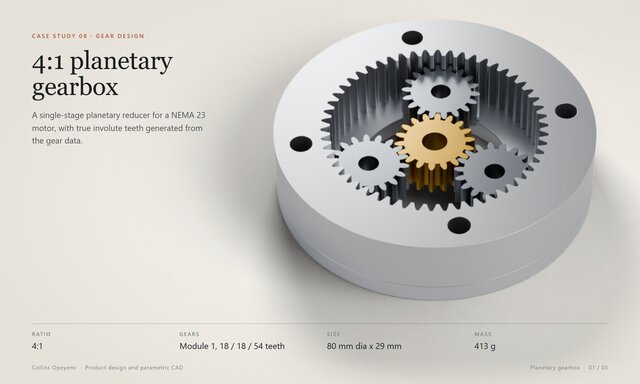
Single-stage planetary gearbox with a 4:1 ratio, sized for a NEMA 23 stepper or servo motor.
Ring gear fixed, sun gear driving, carrier as the output: ratio 1 + 54/18 = 4:1
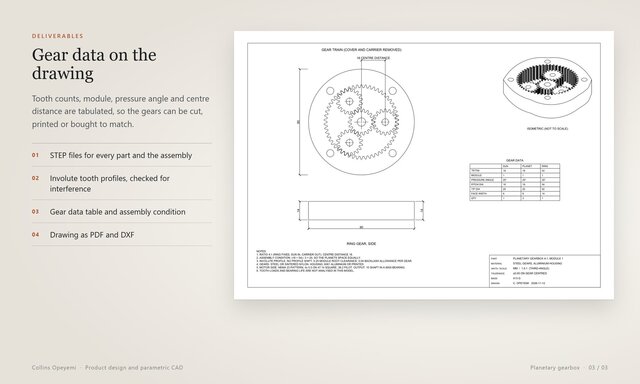
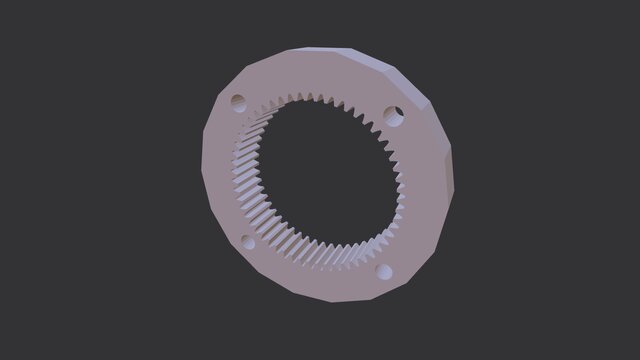
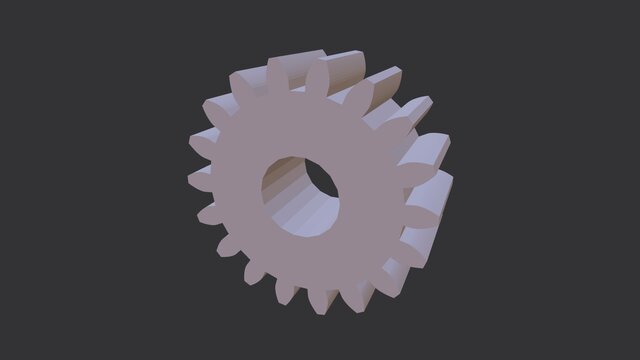
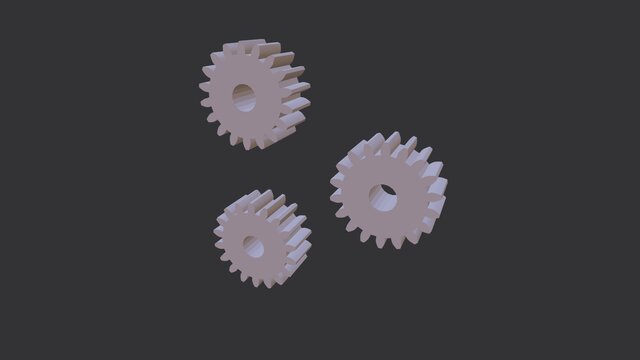
Module 1 involute gears with a 20 degree pressure angle: 18-tooth sun, three 18-tooth planets and a 54-tooth internal ring, on an 18 mm centre distance
Tooth profiles are generated from the gear data, not drawn as approximations, with 0.25 module root clearance and a small backlash allowance. A 2D check finds no tooth interference in the modeled position
Tooth counts satisfy the assembly condition, so the three planets space evenly at 120 degrees
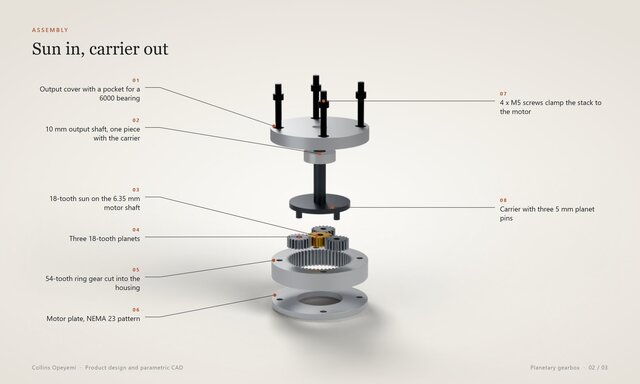
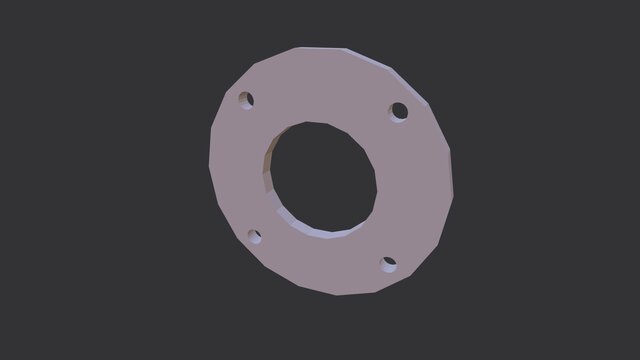
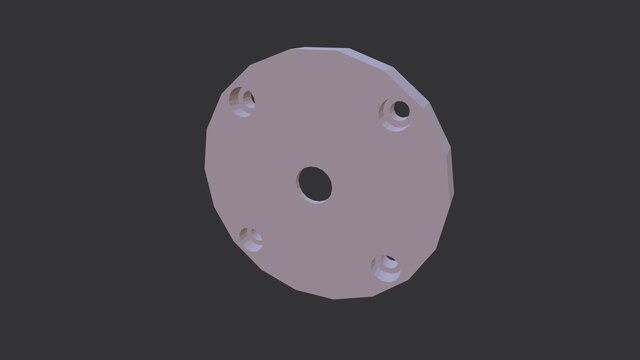
Housing 80 mm in diameter and 29 mm long: motor plate with the NEMA 23 bolt pattern and pilot, ring gear body and an output cover with a pocket for a 6000 bearing
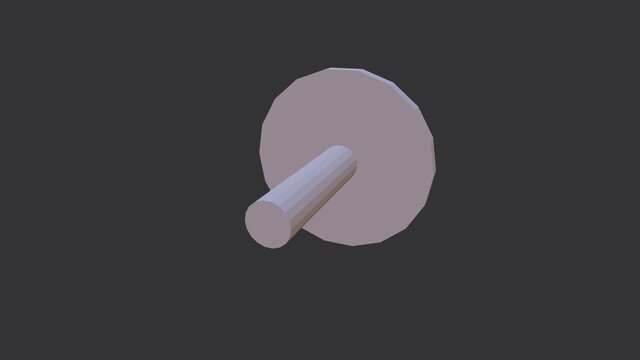
Carrier and 10 mm output shaft in one piece, with three 5 mm planet pins
About 413 g with steel gears and an aluminium housing
Files: STEP for every part and the full assembly (opens in SolidWorks, Fusion 360, Inventor, Creo and Onshape), a drawing with the gear train, gear data table and notes (PDF and DXF) and presentation renders.
This is a geometric design: tooth loads and bearing life are not analysed. The model is parametric, so module, tooth counts, face width and the motor pattern are quick to change. Message me if you need gears or a gearbox modeled with manufacturing drawings.
Files (12)
License:
CC - Attribution - Non-Commercial
Learn more