

Six-Wheel Rocker-Bogie Exploration Rover – Full Assembly

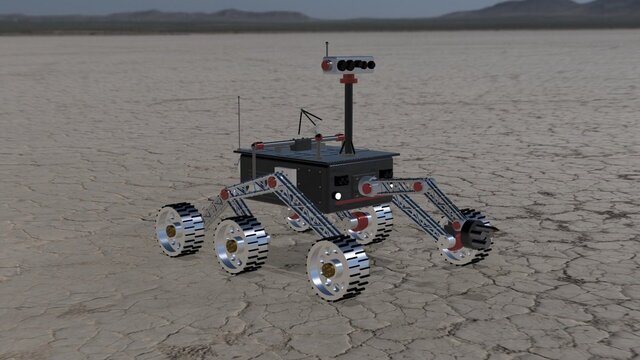
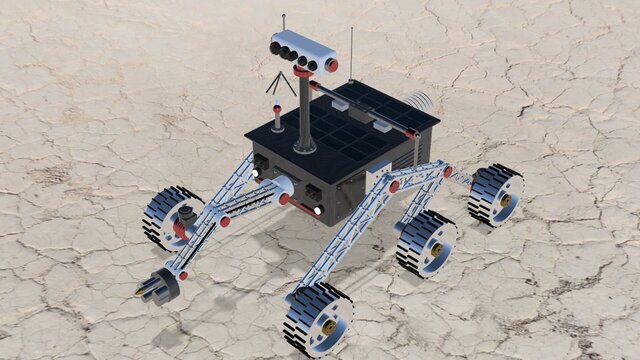
Full mechanical assembly of a six-wheel rocker-bogie exploration rover, designed in Autodesk Fusion 360.
Key features:
- Rocker-bogie suspension with truss-type arms (1096 × 675 mm) and a differential bar linking both sides over the body
- 6 × Ø300 mm wheels with grouser tread
- Chassis 760 × 604 mm with solar panel lid
- Camera mast (581 mm), high-gain antenna on a tripod mount, and a finned power unit housing
- Manipulator arm with 855 mm reach and end effector
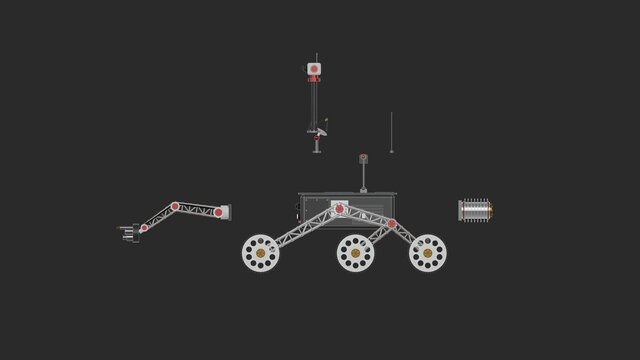
Overall size: 1955 × 1132 × 1183 mm. 14 main sub-assemblies with a 16-sheet technical drawing set and exploded views.
Images: photorealistic render, exploded view and side view.