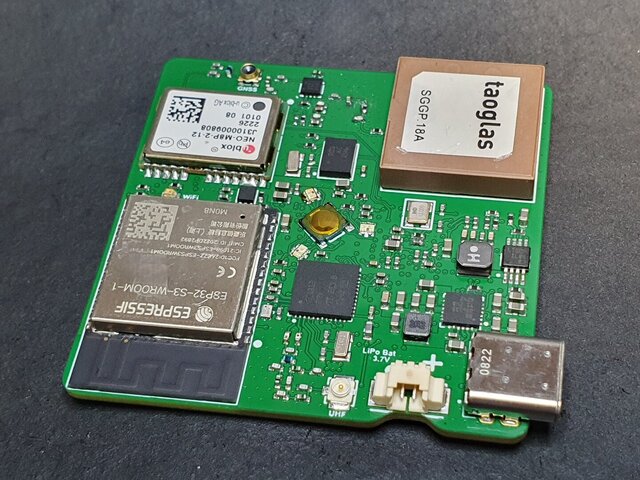

RTK GNSS/IMU Tracker with Dual-MCU Architecture
Challenge: Centimeter-level positioning for a mobile application, with dead reckoning through GNSS dropouts (tunnels, dense foliage) and wireless data backhaul.
Solution: u-blox NEO-M8P for RTK corrections, BNO055 IMU for inertial fill-in, Taoglas active antenna with LNA. Processing split across two MCUs: ATSAM handles real-time sensor fusion and position computation, ESP32-S3 manages Wi-Fi/BLE networking. This separation was deliberate: putting networking and GNSS processing on the same core caused timing jitter in the position solution during Wi-Fi traffic bursts.
Results: Consistently under 3cm CEP in open sky RTK mode. The IMU dead reckoning holds under 1m drift for about 30 seconds of GNSS outage, covering most short tunnel transits.