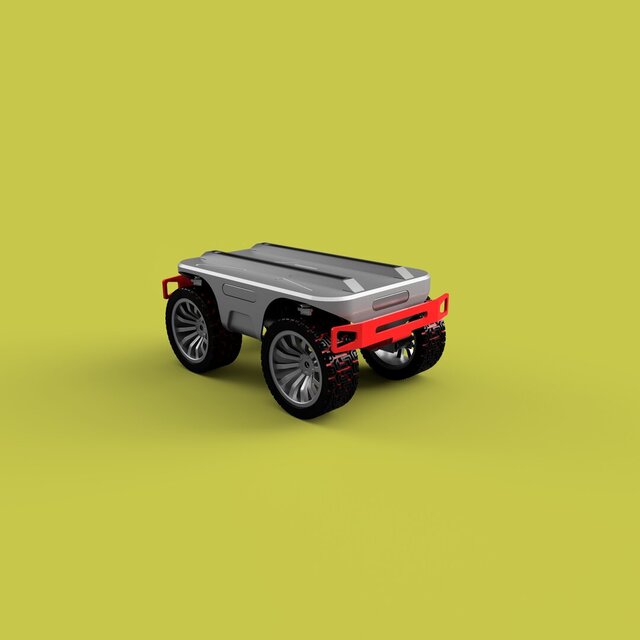
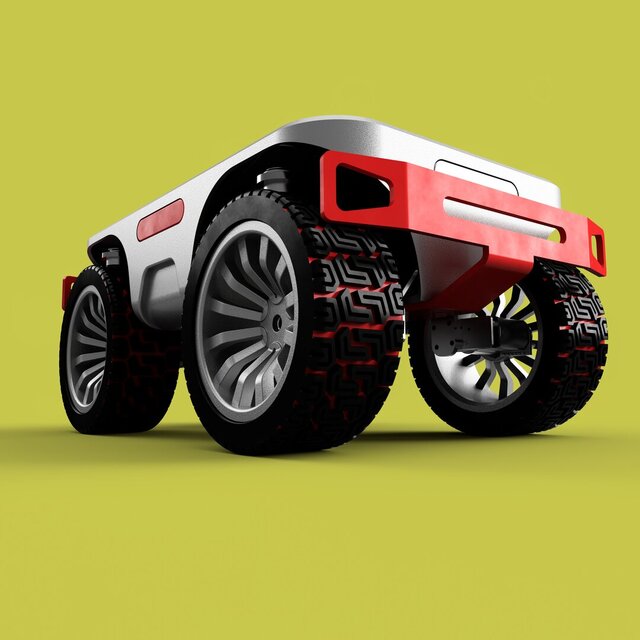
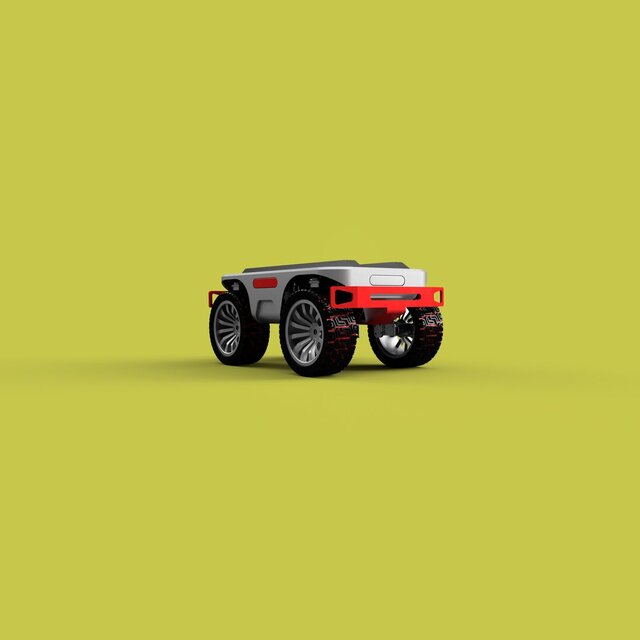


Rover
Mechanical chassis engineered to carry a collaborative robot arm and an ergonomic operator workstation for an industrial inspection system. Work included the wheel/suspension configuration for both outdoor rough terrain and indoor plant floors, structural layout to support the arm's operating envelope and load, an internal electronics cabinet below the deck, and an adjustable monitor/keyboard station sized for standing use. Modeled and refined through multiple engineering iterations in Fusion 360
Files (4)
License:
CC - Attribution
Learn more
Published