

ROBOTICS
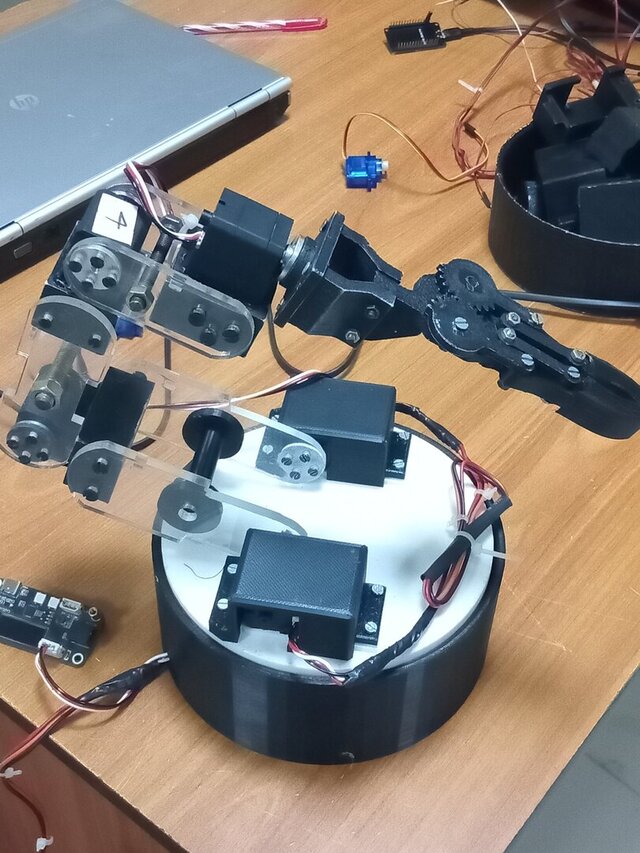
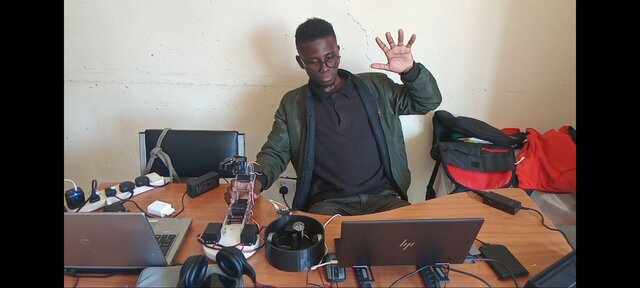
Developed a 5-DOF robotic arm control system using ROS 2, integrating Kinect V2 hand tracking for real-time gesture-based manipulation. Implemented motion control, inverse kinematics, and a digital twin in RViz, with an interactive GUI for live camera feedback and manual control. Improved mechanical stability through a redesigned bearing holder and enabled intuitive gripper control using open- and closed-hand gestures.
Published