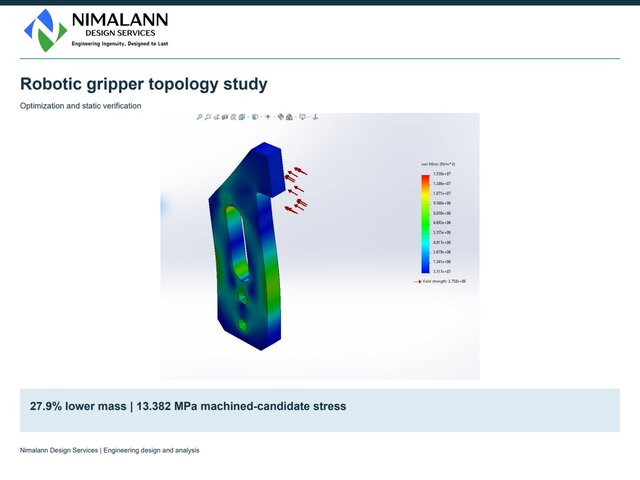


Robotic Gripper | Topology Optimization and FEA
ndseng
 Top Designer
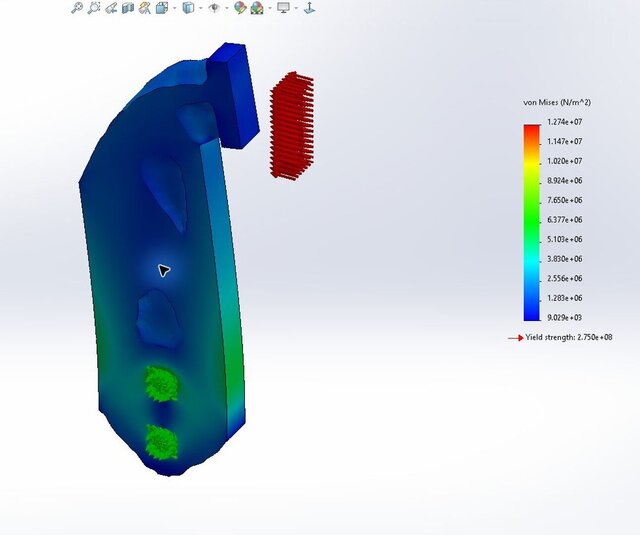
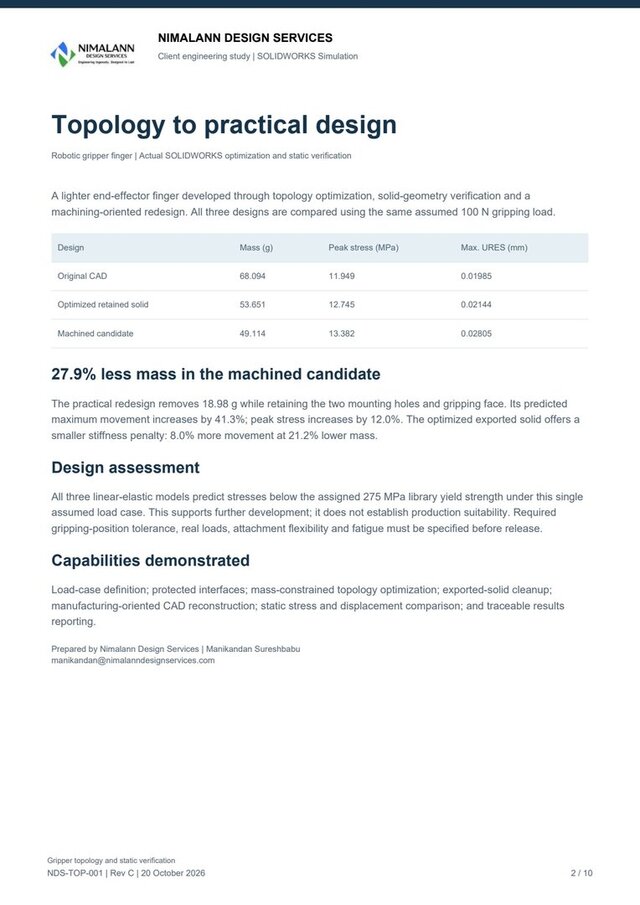
Developed a 6061-T6 robotic gripper finger through topology optimization, exported-solid assessment and machining-oriented CAD reconstruction. Under the same assumed 100 N load, the machined candidate reduced CAD mass by 27.9%, with 13.382 MPa peak von Mises stress and 0.02805 mm maximum displacement. The report compares baseline, optimized-solid and machined designs using native SOLIDWORKS stress and displacement contours, mass and stiffness comparisons, and mesh checks. The static comparison uses fixed-hole supports; confirmed service loads and physical qualification form separate validation stages.
Technical report attached.
Nimalann Design Services
Published