

Robot Demonstration Data & Viewer
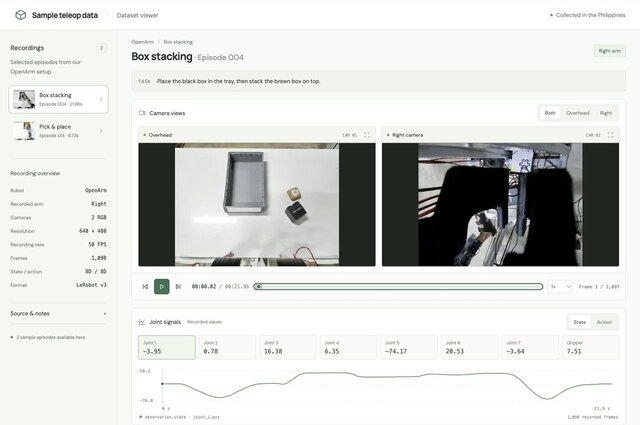
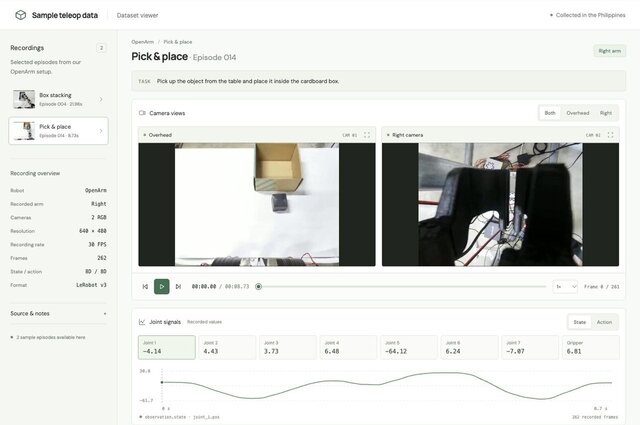
Recorded two short right-arm tasks on our OpenArm: box stacking and pick-and-place. Each sample contains two RGB camera views and robot state/action data.
I built a viewer to replay the recordings and inspect the joint signals. The gallery shows the stacking and pick-and-place recordings in that viewer.
This small in-house sample demonstrates data collection, packaging and inspection.
Published