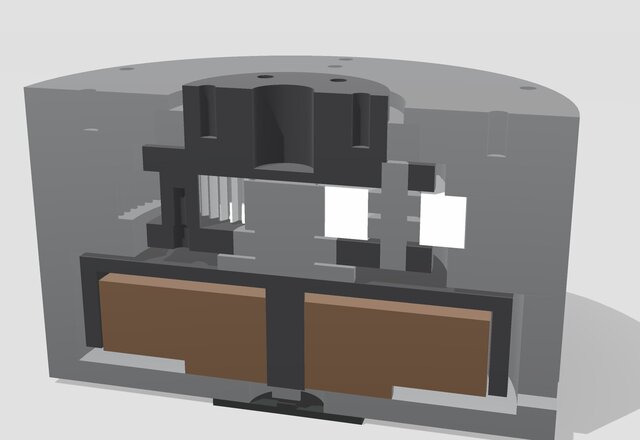
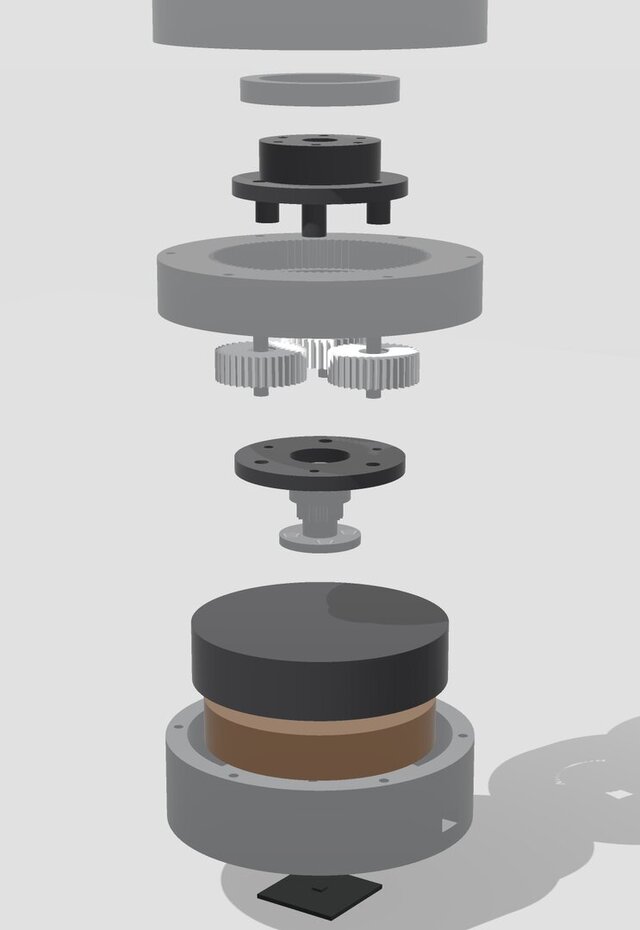
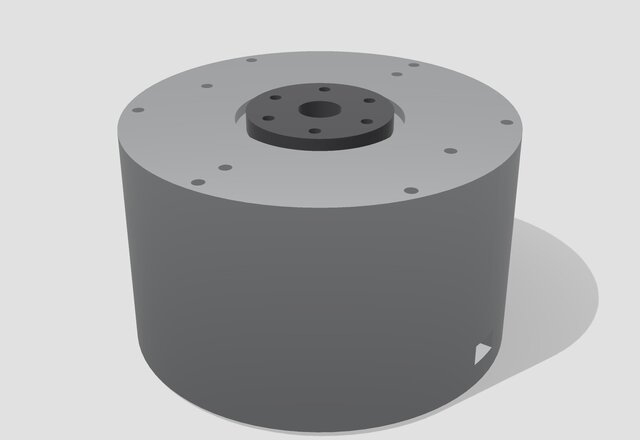


Quasi-Direct-Drive Robot Actuator (6:1 Planetary, 3D-Printable)
Compact quasi-direct-drive (QDD) actuator for legged robots, inspired by the MIT Mini Cheetah actuator concept and redesigned for 3D printing and off-the-shelf parts.
Key specs
- Envelope: Ø108 x 68 mm
- 8108-class outrunner BLDC motor (motor interface is parametric – update to the measured motor before manufacturing)
- Single-stage planetary gearbox, 6:1 ratio: sun 18T, 3 planets 36T, ring 90T, module 0.8 (larger module than the original for stronger printed teeth)
- Double-sided planet carrier, 61808 thin-section output bearing for leg loads
- Magnetic encoder on the motor shaft, 6x M4 output flange
- 24 parts, full BOM included