

Parallel Robotic Gripper - Adjustable Jaws & Interchangeable Pads
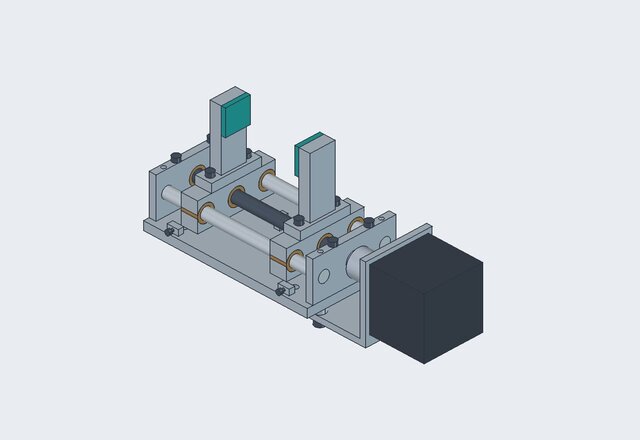
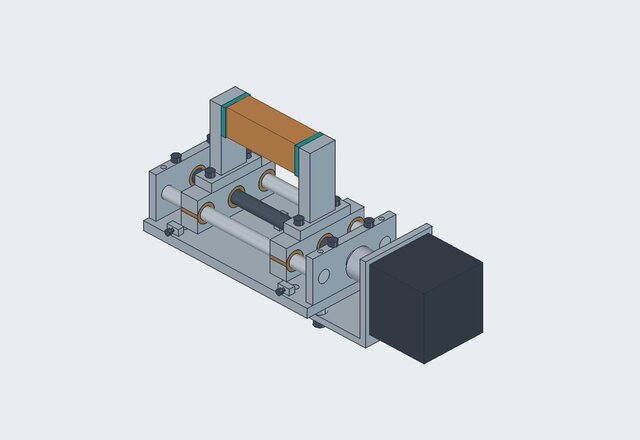
Develop a gripping concept around the shapes it needs to hold. This parallel-jaw gripper uses an opposed screw arrangement and interchangeable flat, V-groove and curved pads, with editable opening, finger length, pad thickness and mounting dimensions.
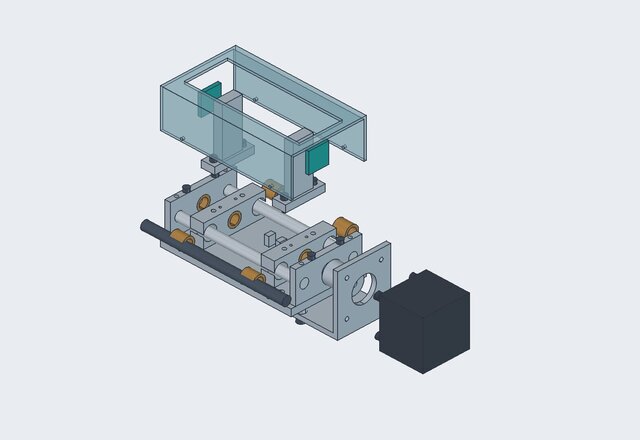
The package includes a FreeCAD assembly, STEP files, selected prototype STL parts, drawings and exploded/section views. Parameter changes and exported geometry were checked digitally.
Send your part dimensions, contact requirements and mounting constraints through Cad Crowd to discuss a gripper or mechanism CAD study.
Portfolio concept: screw and purchased-part details are simplified, and the demonstrated motion is prescribed. Grip force, backlash and cycle life require physical testing.
Published