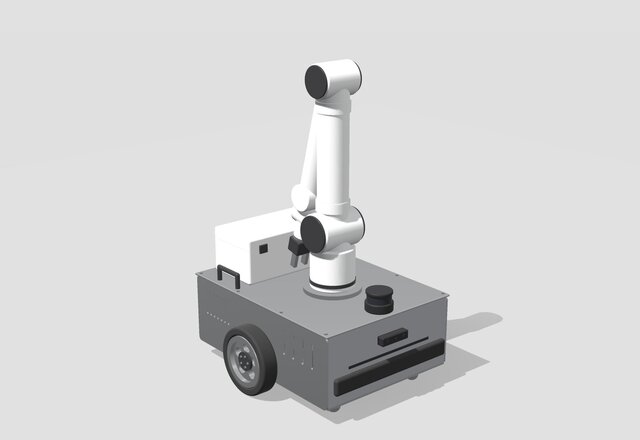
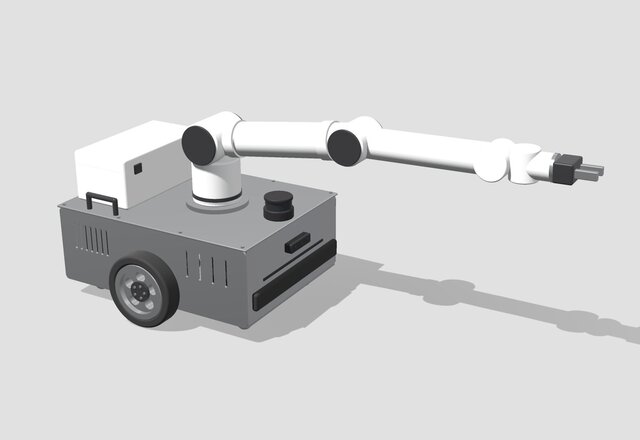


Mobile Manipulator – Drivetrain Sizing & Stability Study
Functional prototype study: a differential-drive mobile base carrying an off-the-shelf 6-DOF arm (850 mm reach, 5 kg payload) plus onboard equipment.
Drivetrain sizing from real calculations
- Mass budget from the CAD model: 73.8 kg incl. payload
- Wheel forces for 1 m/s, 0.5 m/s² acceleration and a 5° ramp: 114 N peak
- Per wheel: 5.7 N·m peak, 95 rpm → 24 V BLDC 150–200 W with 30:1 planetary gearbox, encoder feedback
- Traction check: required μ 0.24 vs ~0.5–0.7 for PU wheels on hard floors
- Battery: 320 W average load, 4 h runtime → 25.6 V LiFePO4 80 Ah
- 2-channel 24 V FOC motor controller with encoder input and CAN/serial
Tip-over stability
- Arm fully extended with payload, swept 360°: stable in all directions, including braking at 0.5 m/s² and standing on a 5° slope (minimum margin 49 mm)
- 2 driven wheels + 4 sprung ball casters for a wide support polygon
Published