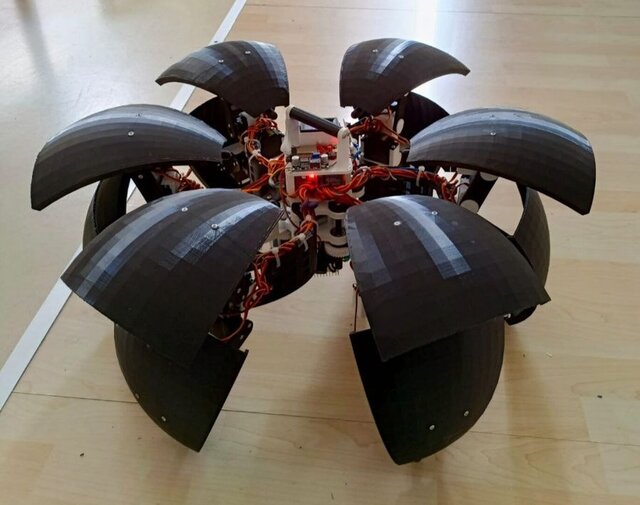

HEXPLORER — Dual-Motion Modular Exploration Robot (Main Module)
Graduation project (TÜBİTAK 2025) — independently designed and built end-to-end. HEXPLORER is a hybrid exploration robot that transforms between hexapod walking and spherical rolling modes. This is the main module, containing the core structure and 30 synchronized servos that drive the hexapod-to-sphere transformation. Mechanical design was done in SolidWorks and Onshape, with custom C firmware handling motion synchronization, sensor feedback, and stability control during transitions.
Files (2)
License:
CC - Attribution
Learn more