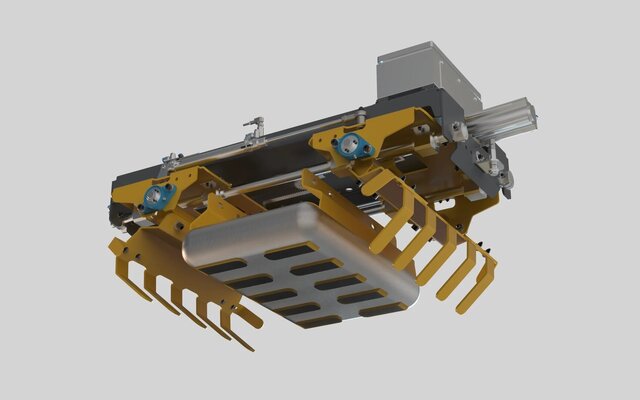
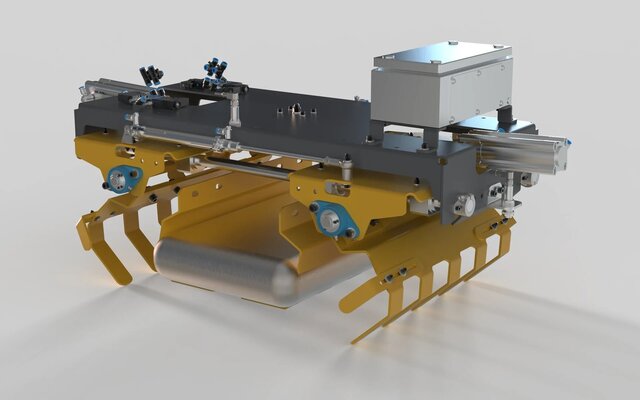
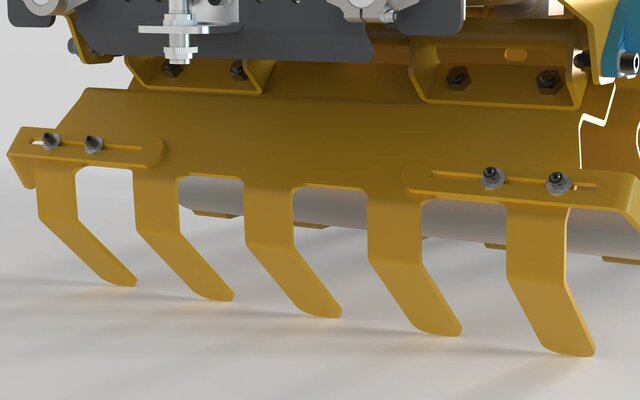
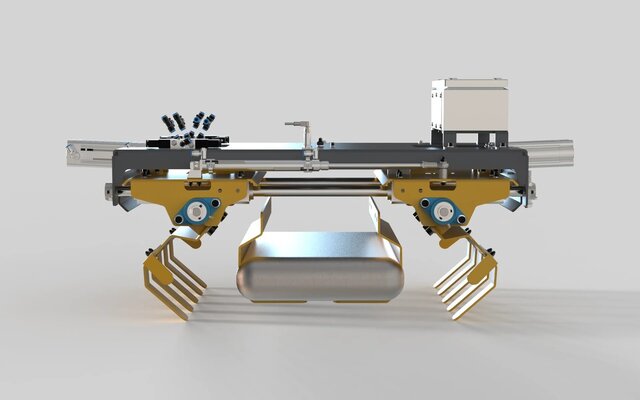
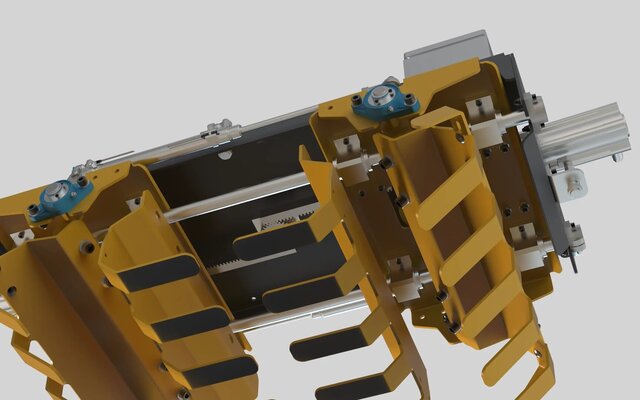


Bag Gripper for ABB IRB 460 Robot
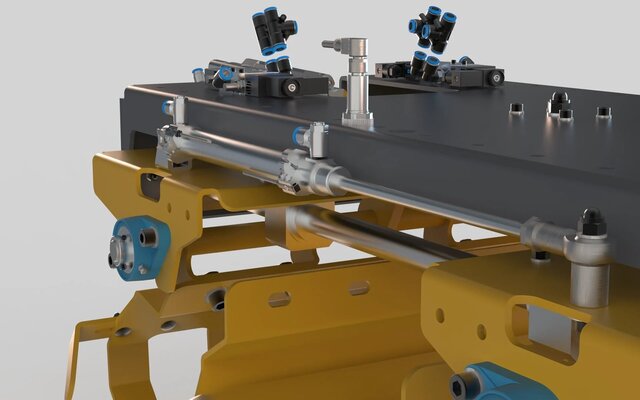
Two jaws driven by separate air cylinders could drift apart. I coupled them with a rack and pinion (m2, z30) inside the existing assembly and issued DIN-ISO drawings. 100 mm jaw stroke. My role: design engineer.
Published