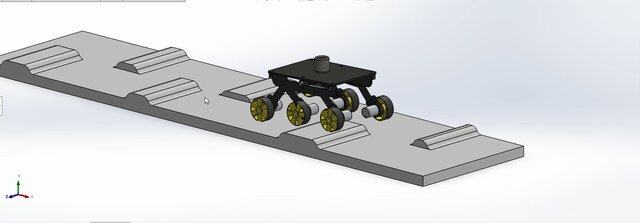

6-Wheel Rover with Independent Suspension
Six-wheel rover platform designed for a private client, featuring independent suspension per wheel to handle uneven and obstacle-laden terrain, with a mass capacity of 2.5 kg. Motorized wheel drive with a central chassis-mounted enclosure for electronics/payload. Modeled and motion-simulated in SolidWorks to validate suspension travel and obstacle traversal. Delivered to client for design review and mechanical integration. Published with client permission.
Published