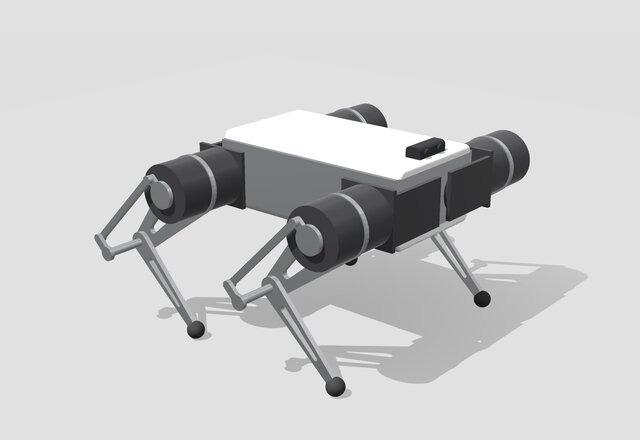
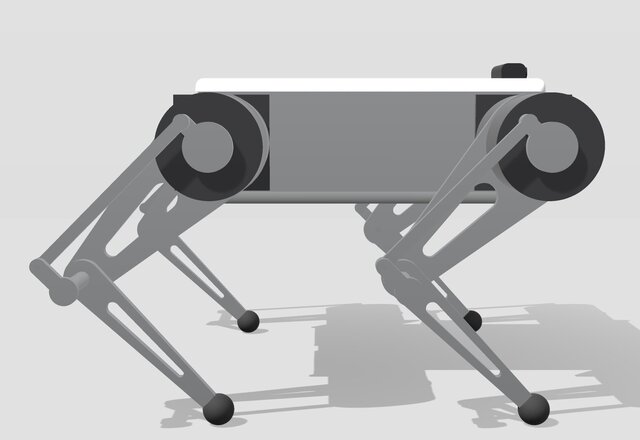
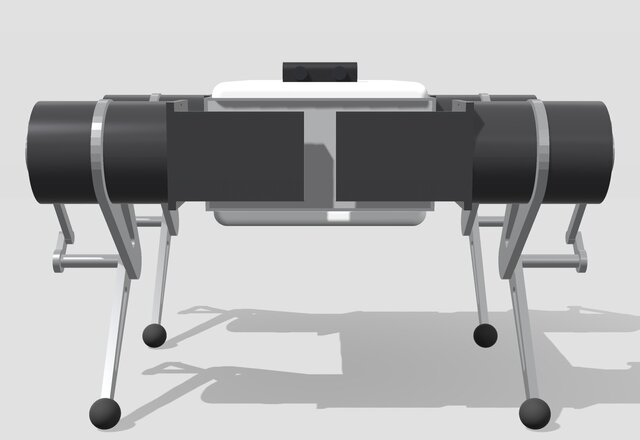


12-DOF Quadruped Robot Dog with QDD Actuators
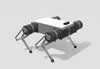
Medium-size quadruped robot concept built around 12 custom quasi-direct-drive (QDD) actuators (6:1 planetary, Ø108 mm – see my QDD actuator design). All four knees point backward, Mini-Cheetah style.
Layout
- Overall size (standing): 570 x 638 x 395 mm, 92 parts
- 3 DOF per leg: ab/ad actuator inside the body, hip actuator beside the body, knee actuator mounted coaxially on the thigh
- Knee driven by a 1:1 parallelogram push-rod linkage – no belts, easy to build and service
- Thigh and shank: 200 mm each, tapered aluminium links with lightening slots, rubber ball feet
- Body: aluminium side plates, printed end plates and bulkheads, rounded top and belly covers, central battery bay (6S) and controller mount, front stereo camera module
Published